KY

Kai Yu

Robotics Engineer

Building systems that perceive, learn, and move.

M.S.E. Robotics · University of Pennsylvania

About

I'm an M.S.E. Robotics student at the University of Pennsylvania, working at the intersection of robot perception, control, and machine learning. I enjoy connecting ideas in code with systems that operate in the physical world.

At ModLab, I work on HAMR's perception and control, including visual localization and ball-caster motion analysis. With Xlabs, I'm investigating learning signals for image-editing policies. My broader interests include generative world models and how agents learn to predict and act.

Research

  1. Image Editing Policy Research

    Investigating learning signals for image-editing policies through conditional generative modeling. My current work combines representation-distribution matching with vision-language feedback to study semantic alignment, image quality, and diversity.

    • PyTorch
    • Vision-Language Models
    • Generative AI
    • LoRA
  2. HAMR: Holonomic Mobile Robotics

    Developing perception and control tools for HAMR, from vision-based analysis of a custom ball caster to visual SLAM and localization with a RealSense D455 depth camera. The work connects caster motion estimation, sensor integration, and PID control to investigate mobile robot behavior.

    • Computer Vision
    • SLAM
    • ROS 2
    • PID Control
  3. Generative World Models

    Researching world models for agent-centric prediction and decision-making, including current-state and latent dynamics formulations. Developing flow- and diffusion-based models for controllable sequence generation, with preliminary exploration of energy-based models.

    • Python
    • Diffusion Models
    • Generative AI

Experience

  1. Robotics Intern

    Implemented autonomous yard patrols using a quadruped robot, enabling waypoint navigation, dynamic obstacle avoidance, sensor-based image capture, and web-based monitoring and control. Created full-stack AI guest check-in system, supporting visitor/employee appointments and real-time status tracking.

    • C++
    • Unitree
    • ROS2
    • React
  2. Software Engineer Intern

    Developed a Python web scraper using Scrapy to extract and process over 100 million data hashes, storing results in PostgreSQL. Authored a software requirements specification outlining system functionality, technical requirements, and project scope.

    • Python
    • PostgreSQL

Selected projects

Dual-camera caster tracking with geometry overlays, a 3D model, and rotation estimates

ModLab · Mobile robotics

HAMR

Connecting caster mechanics, visual sensing, and feedback control in a holonomic mobile robot. Work spans dual-camera caster tracking, depth-camera localization, and ROS 2 / embedded PID control.

  • ROS 2
  • Computer Vision
  • SLAM
  • PID Control
Explore project
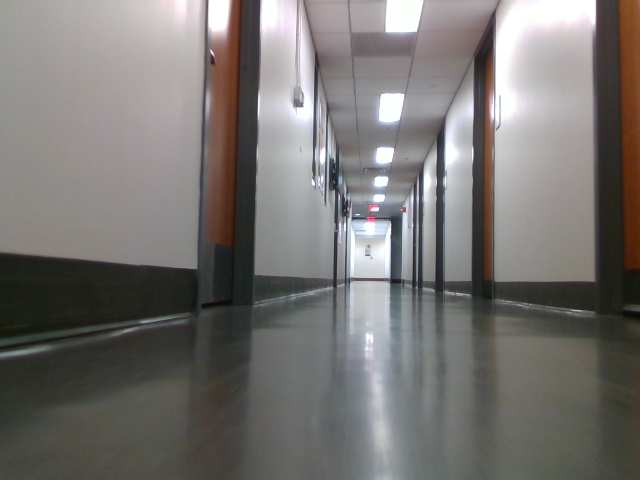
Indoor corridor captured as an RGB input for scene reconstruction

3D reconstruction · Robot perception

F1-3DGS

Exploring 3D Gaussian Splatting for indoor scene reconstruction from RGB-D lap recordings, calibrated camera data, and robot poses.

  • 3D Gaussian Splatting
  • RGB-D
  • Open3D
Explore project
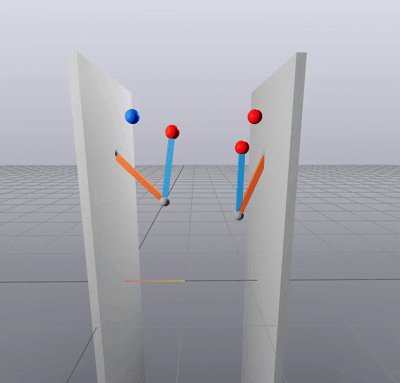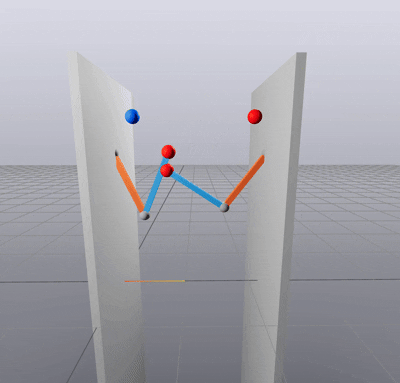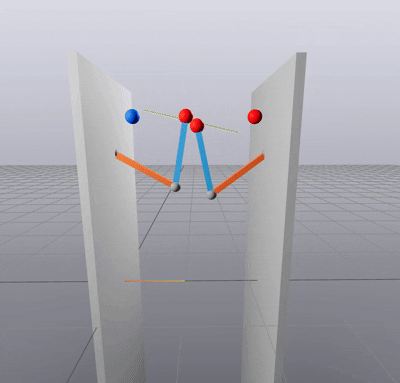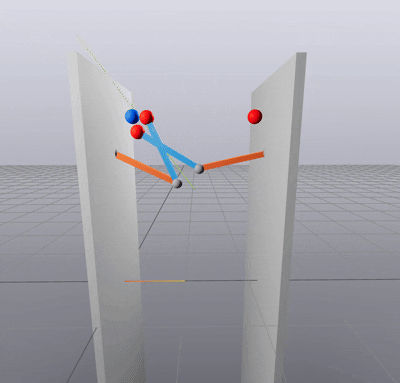
RoboRocky

Robotics · Optimal control

RoboRocky

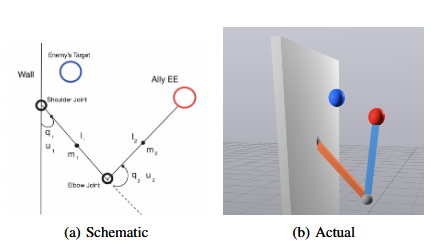
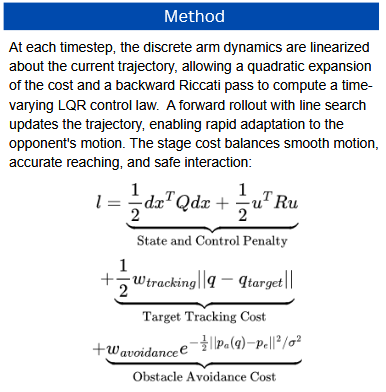
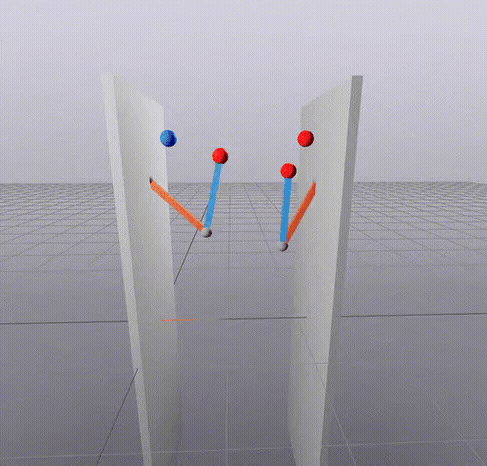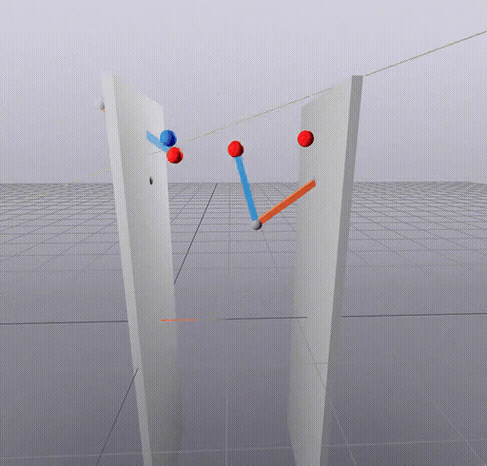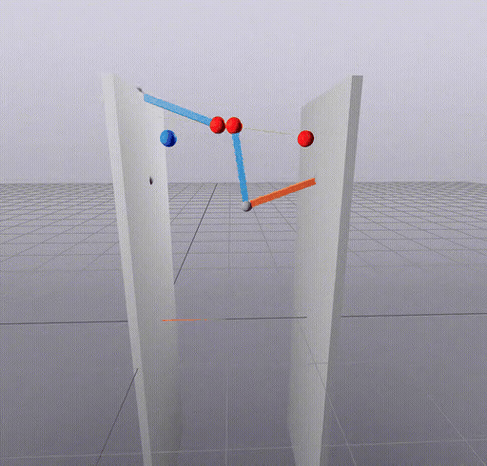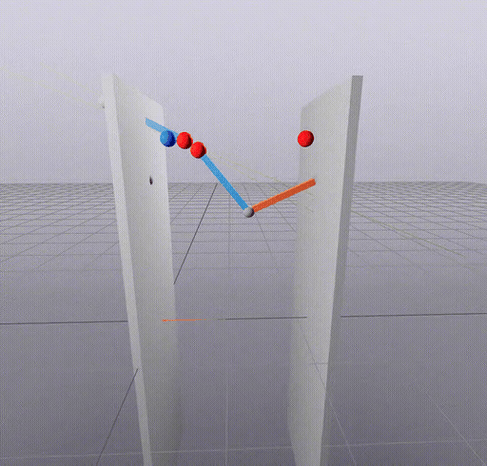
Developed a planar boxing-arm simulator that uses Model Predictive Control with iLQR to generate fast, contact-rich attack, block, and parry motions between two opposing robotic arms. The system demonstrates real-time trajectory optimization and adaptive defensive behaviors.

  • Python
  • MPC
  • Controls
View all projects
Kai Yu Robotics & machine learning